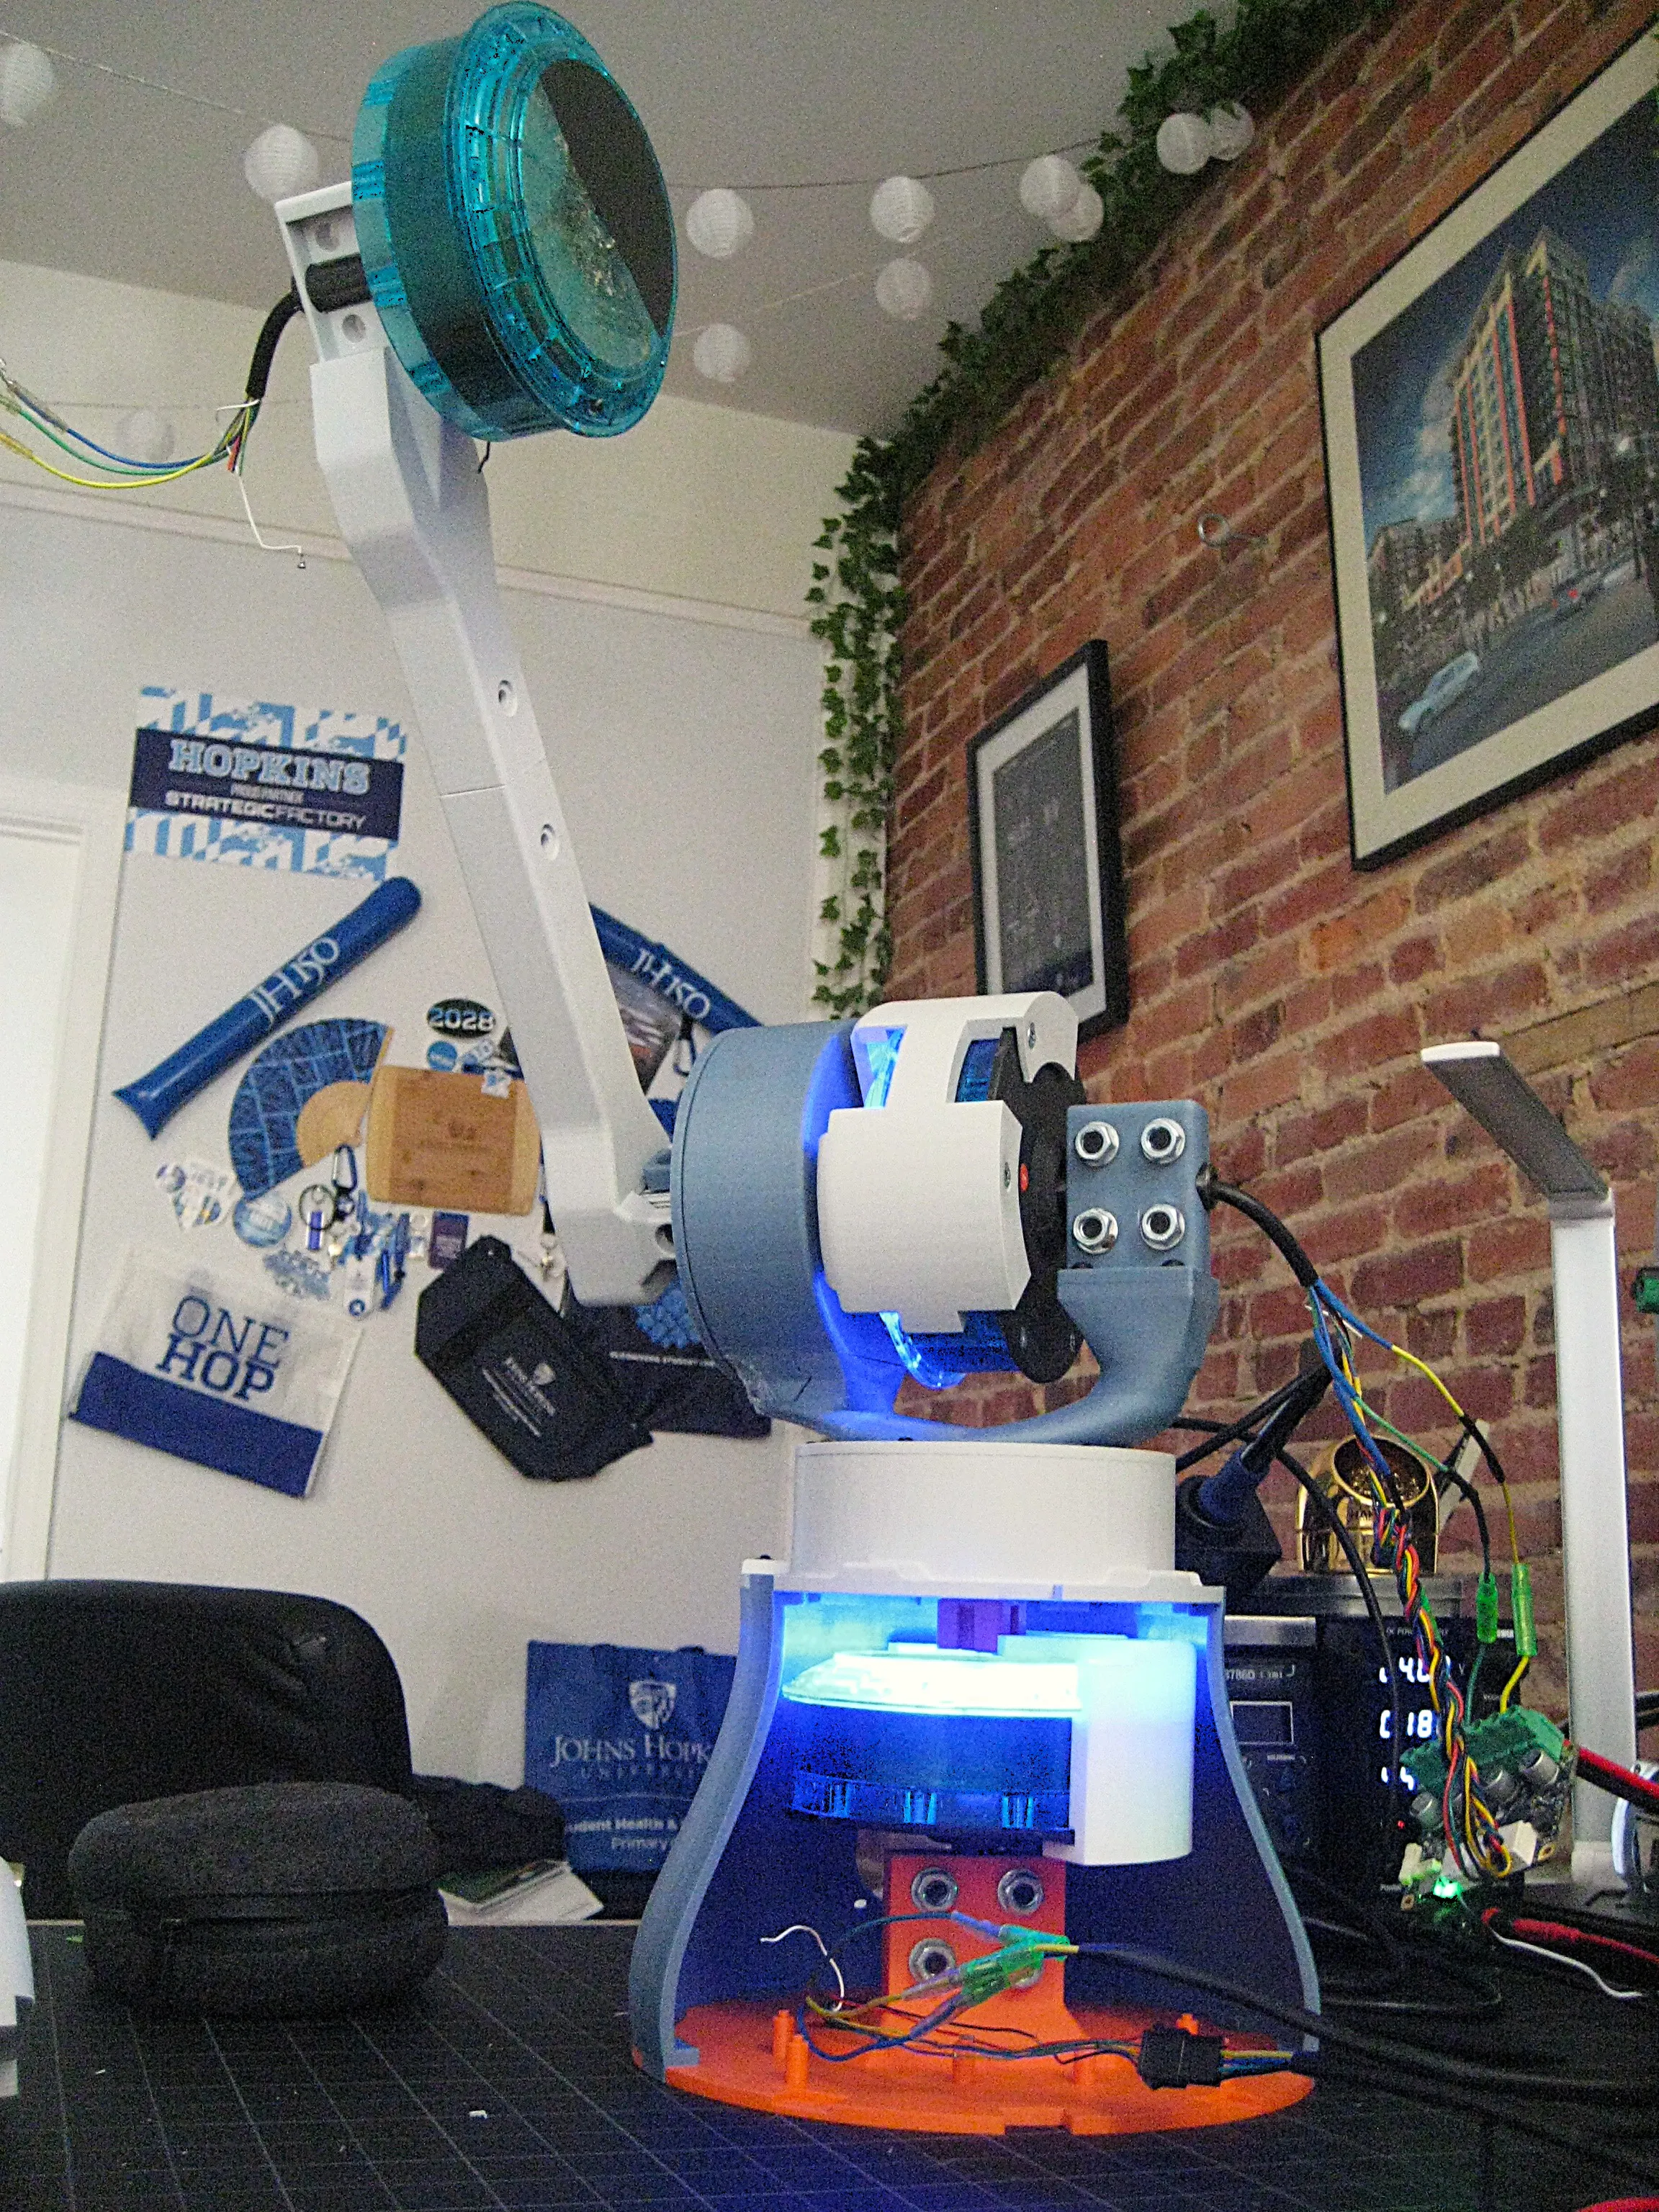
Robotic Arm
6-DOF Robotic Arm: ODrive S1 CAN Control
I’m building a 6-axis DOF robotic arm from scratch as a way to learn how robot arms are designed and controlled. The video shows where the project currently stands. The long-term goal is an arm that runs autonomously with onboard trajectory planning and computer vision to complete trained task like, orginizing my desk. The hardware consiste of three hoverboard BLDC motors, each driven by an ODrive S1, to power the high-torque joints (base, shoulder, elbow). The plan is to add three NEMA17 steppers (likely TMC2209-driven) to handle the wrist.
Mechanical: I designed and redesigned most of the parts myself, including 36:1 gearboxes that were chosen more for positional accuracy than for extra torque. The deisgning of each part has taken the majority of the time but has allowed me to become very proficent in Solidworks or just general mechanical design
Motor bring-up: I configured the ODrive S1s (firmware v0.6.11) for PMSM current control with Hall feedback, ran and saved the full calibration sequence, and verified closed-loop velocity control.
Software: I have just started development on some short scripts My latest script commands multiple ODrive either by command inputs or repetative loop of a sinewave. The loop is what is running in the video